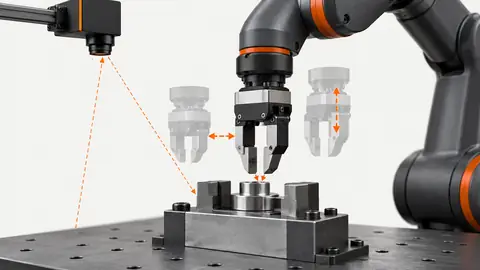
Nominal camera rate and robot speed cannot predict station throughput. Measure the period between consecutive completed picks and the stages that block the next pick. Use the real gripper and representative load.
Loading the right vibration recipe is insufficient if the camera model, tray or gripper belongs to another part. Treat changeover as a controlled set of mechanical and software identifiers rather than a single file.
A lively tray is not proof of useful feeding. Optimize parts that the gripper can actually pick, not vibration amplitude alone. Use the production tray, representative parts and a stable camera view.
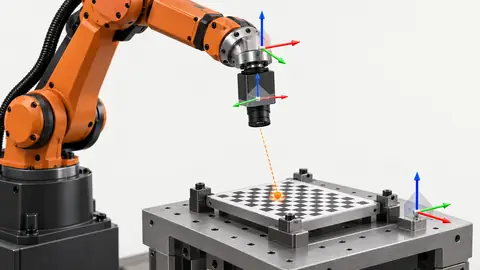
A low fitting error at taught points does not prove accurate picking elsewhere. This tutorial concerns a fixed-camera planar XY arrangement; a 3D or moving-camera system needs its own calibration model.
Repeated recalibration can hide a bad TCP or a wrong picking plane. Separate image localization, coordinate transformation and gripper mechanics. Use the robot’s authorized commissioning procedure for physical movements.
No tutorial titles match this search.
Engineering review
Bring the inspection problem and the evidence.
Send sample images, your current setup and the check that failed. Include field of view, working distance, line speed and acceptance criteria for a practical review.