
When to review machine vision lighting.
The Machine Vision Lighting route fits surface defect contrast, edge measurement, reflective part inspection projects. Start from material and defect type.
Product route
Ring, bar, coaxial, dome, backlight, dark-field and line-light routes matched to defect contrast, edge clarity and part surface behavior.
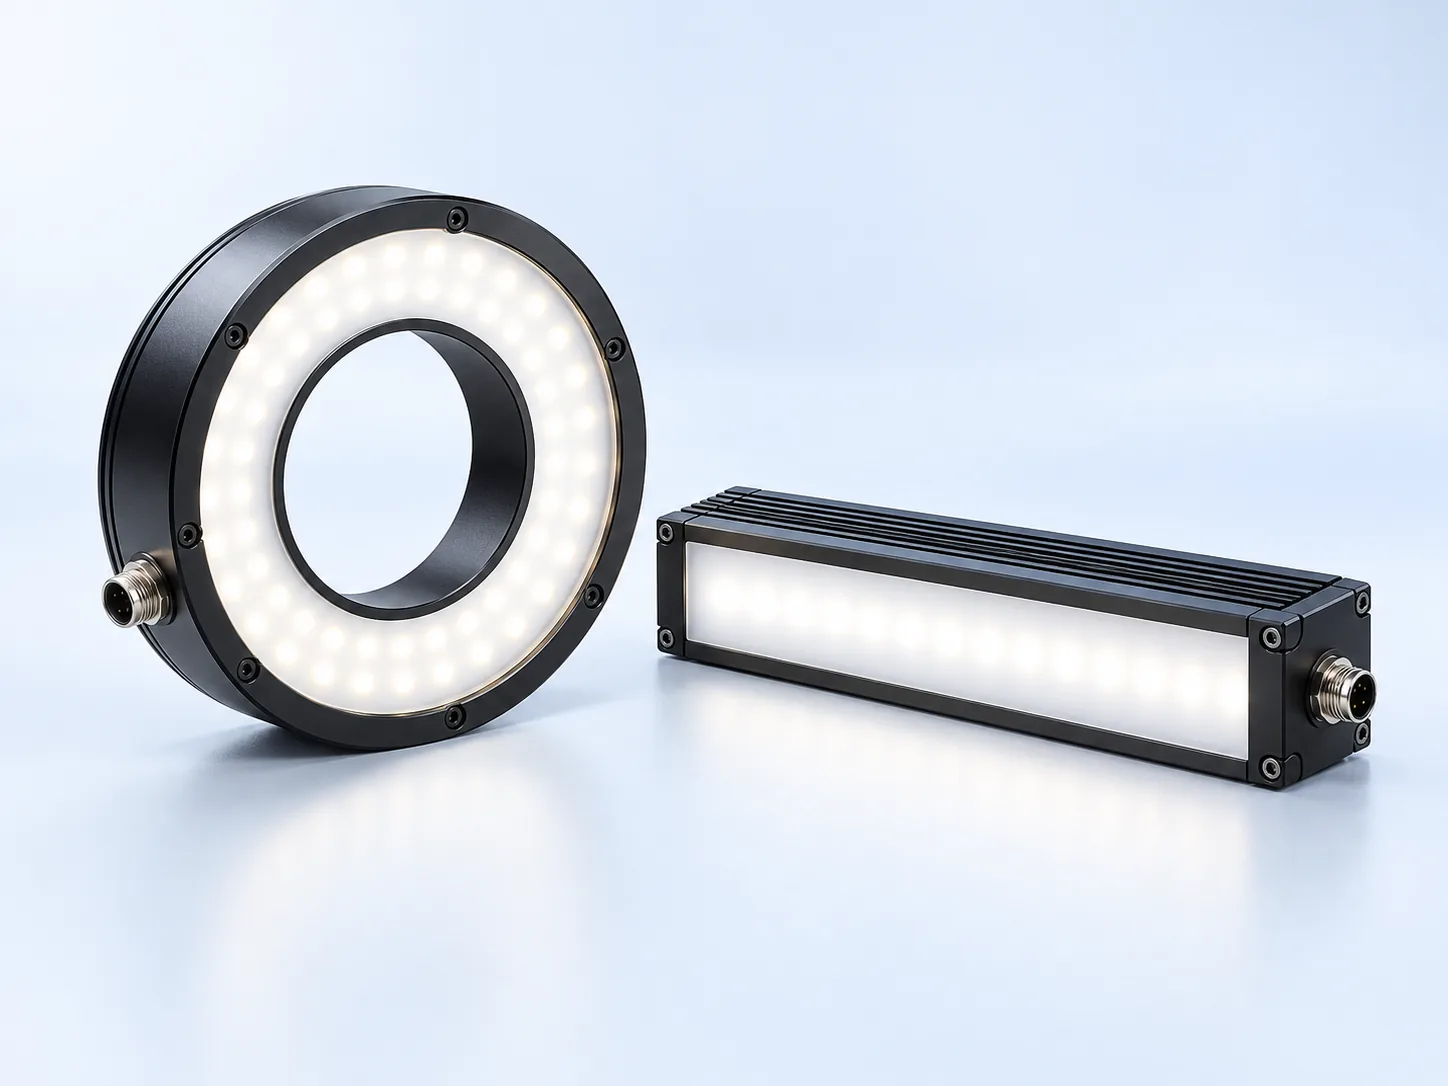
The Machine Vision Lighting route fits surface defect contrast, edge measurement, reflective part inspection projects. Start from material and defect type.
Ring / bar / dome, Coaxial / backlight, Controller-ready are only the starting point. Also confirm field of view, working distance, line speed, interface, trigger timing and mounting limits.
Suppressing a bright reflection is useful only if the defect remains visible. Compare unpolarized and cross-polarized images on the same scratched and good surfaces.Run a polarization A/B test for glare
Share sample images, good and bad parts, current reference model, target defect, tolerance, production speed and available fixture space.
When this route is a good fit
Swipe horizontally to compare buyer situation, inspection constraint, recommended route and what to send.
| Buyer situation | Inspection constraint | Recommended route | What to send |
|---|---|---|---|
| Lighting-first selection before camera model lock | Unstable image contrast review | Lighting-first selection before camera model lock. | Send material, defect type, surface reflectivity and working distance. |
| LED ring, bar, dome, coaxial, backlight and line-light routes | LED light type and controller review | LED ring, bar, dome, coaxial, backlight and line-light routes. | Confirm color, strobe need, controller route and mounting space. |
| General front-light review for presence, label and moderate texture checks | General front-light inspection review | General front-light route for presence, label and moderate texture checks. | Send sample images showing glare, shadow and target feature size. |
| Low-angle or dark-field review for scratches, edges and raised defects | Scratch and edge-contrast review | Low-angle or dark-field route for scratches, edges and raised defects. | Provide defect direction, surface finish and line-speed condition. |
How buyers should compare this route
Machine Vision Lighting should be evaluated when the project is tied to surface defect contrast, edge measurement, reflective part inspection. A useful review starts from the part behavior, target feature, motion condition and current failure mode, then maps those limits to the right component family instead of forcing one catalog model.
Use machine vision lighting selection as a system decision: lens, lighting, fixture, trigger, interface and software all affect repeatability. The safest shortlist is created only after sample images, line speed and output constraints are reviewed together.
What engineering should confirm first
This workflow keeps the RFQ focused on the real inspection constraint and reduces the risk of buying a component that works on paper but fails under production lighting, motion or fixture variation.
Reviewed selection basis

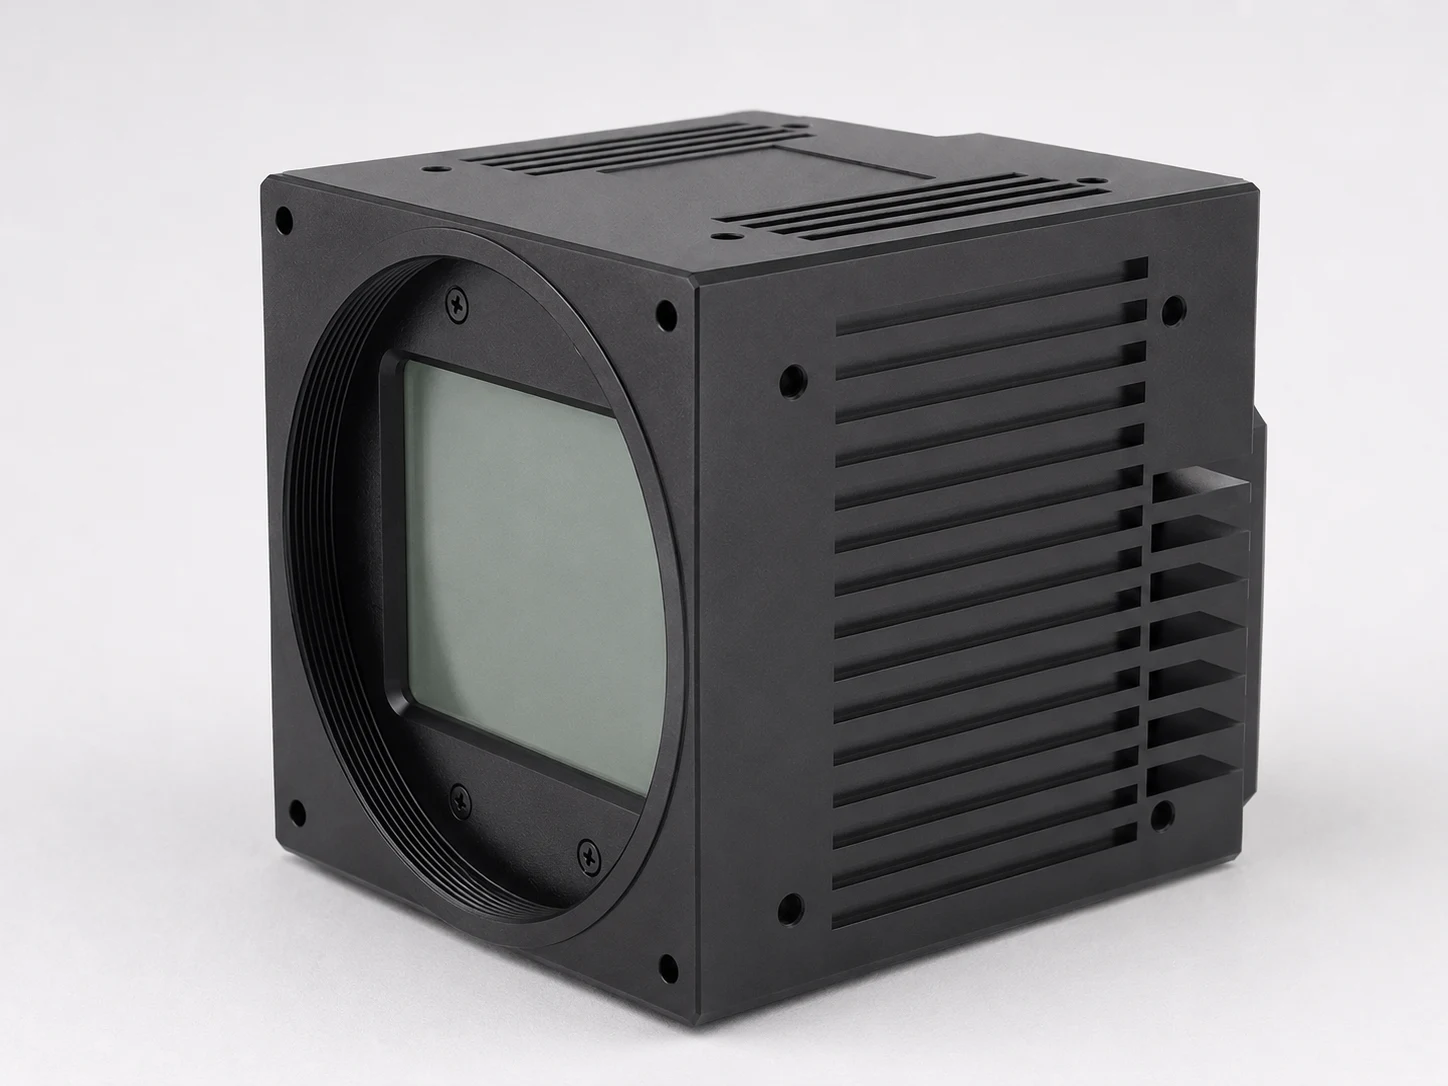
Model parameter matrix
Reference model: CST-RS3475-W · Supplier: CSTMV / KST
Manufacturer specs reviewed Official spec page Request this routeReference model: CST-HFS200150-W · Supplier: CSTMV / KST
Manufacturer specs reviewed Official spec page Request this routeReference model: CST-DS500-W · Supplier: CSTMV / KST
Manufacturer specs reviewed Official spec page Request this routeSwipe horizontally to compare reviewed model parameters. Use the mobile cards above on small screens.
| Parameter | Ring light DY-RS3475-W Reference model: CST-RS3475-W · Supplier: CSTMV / KST Manufacturer specs reviewed Official spec page | Flat back light DY-HFS200150-W Reference model: CST-HFS200150-W · Supplier: CSTMV / KST Manufacturer specs reviewed Official spec page | Dome shadowless light DY-DS500-W Reference model: CST-DS500-W · Supplier: CSTMV / KST Manufacturer specs reviewed Official spec page |
|---|---|---|---|
| Color | White | White | White |
| Power | 2W | 25W | 242W |
| Light opening | 34mm outer / 10mm inner / 19mm height | Confirm during RFQ | Confirm during RFQ |
| Color temperature | 6000-10000K | 6000-6500K | 6000-6500K |
| Use environment | 0-40 C | 0-40 C | 0-40 C |
| Storage environment | -20-60 C, 20-85%RH non-condensing | -20-60 C, 20-85%RH non-condensing | -20-60 C, 20-85%RH non-condensing |
| Rated life | White 30000h @25 C to 50%; red 60000h @25 C to 50% | White 30000h @25 C to 50% | White 30000h @25 C to 50% |
| Warranty | 1 year | 1 year | 1 year |
| Light area | Confirm during RFQ | 200 x 150mm class | Confirm during RFQ |
| Dome class | Confirm during RFQ | Confirm during RFQ | 500mm series |
| RFQ notes |
|
|
|
Related solution routes
Build automated visual inspection systems for defect detection, presence checks, surface inspection, orientation, measurement and repeatable pass/fail output.
SolutionPlan a complete vision inspection system for defect checks, presence, measurement, barcode reading and pass/fail output.
SolutionUse calibrated lenses, lighting and cameras to stabilize measurement under production conditions.
SolutionSelect readers and lighting for label codes, DPM marks, carton sorting and part tracking.
SolutionBuild flexible small-part loading cells with F/FL/FS feeder trays, optional storage bins, vision positioning and DTA robot pickup routes.
Application case briefs
Application route for scratches, burrs, dents and reflective metal surface checks using lighting-first machine vision selection.
Electronics inspectionApplication brief for checking connector pin presence, orientation and bent-pin risk with camera, lens and controlled lighting.
Packaging inspectionApplication brief for label presence, barcode read rate and packaging traceability on moving conveyor lines.
Metal and surface inspectionApplication route for DPM barcode reading on machined or laser-marked metal parts with difficult surface contrast.
Battery inspectionApplication route for battery tab, weld and height checks where 2D contrast alone may not prove geometry.
Textile and web inspectionApplication brief for continuous web, film, textile or paper defect inspection using line scan cameras and line lighting.
Dimension measurementApplication route for fast dimensional checks on stamped, machined or molded parts using instant measuring systems.
Related buying guides
Select lighting for reflective metal scratch, burr and surface defect inspection by glare behavior, defect direction, camera angle and acceptance evidence.
ResourceCompare line scan and area scan cameras by motion type, material width, defect size, encoder timing, lighting stability and integration risk.
ResourceChoose machine vision lighting by surface finish, defect direction, camera angle, working distance and acceptance evidence instead of choosing by light shape alone.
ResourceBreak down cameras, lenses, lighting, controllers, software, I/O and fixtures in an industrial vision system.
ResourceSelect fixed industrial barcode readers by code type, module size, read distance, line speed, lighting route, trigger timing and no-read handling.
ResourceChoose a machine vision supplier by application engineering, sample testing, component route coverage, export support and integration documentation.
ResourceSelect industrial cameras for machine vision by sensor size, shutter type, resolution, interface, frame rate and lighting constraints.
ResourceCompare backlight and coaxial machine vision lighting for silhouette measurement, flat reflective surfaces, printed marks and surface feature contrast.
ResourceChoose between ring light and dome light by surface reflectivity, shadow control, curvature, defect type, working distance and mechanical space.
ResourceCompare ring, bar, dome, coaxial, backlight and line lighting types by surface behavior, defect contrast and installation constraints.
ResourceSelect a barcode reader for manufacturing by code type, takt time, conveyor speed, read distance, trigger timing, PLC output and no-read handling.
ResourceSelect fixed code readers by worst-case code quality, read distance, motion, lighting, trigger timing and output protocol.
ResourcePlan direct part mark code reading by material, mark type, contrast, lighting angle and reader mounting conditions.
ResourcePlan fixed mount barcode reader setup by code size, conveyor speed, trigger method, mounting angle, lighting, DPM difficulty and read-rate target.
ResourceCollect the details engineering teams need before requesting cameras, lenses, lighting, readers or inspection systems.
ResourceUnderstand how working distance affects field of view, lens choice, lighting geometry, fixture design and inspection stability.
ResourcePlan line scan camera lighting by material width, web speed, exposure time, line light geometry, lens field width, encoder synchronization and edge-to-center uniformity.
ResourceUnderstand line scan camera price drivers including sensor length, line rate, interface, lens, line light, encoder, controller and web-inspection scope.
ResourcePlan a line scan camera with encoder synchronization by web speed, pulse rate, roller diameter, line rate, exposure and image scale stability.
ResourceDesign a visual inspection system by defining defect criteria, sample set, optics, lighting, fixture, trigger, I/O and acceptance tests.
ResourceDefine machine vision acceptance tests with good/bad samples, repeatability checks, false-pass risk, read-rate targets, station timing and integration handoff notes.
ResourceDesign packaging label and barcode inspection for wrong-label risk, no-read events, label position, print verification, conveyor speed and reject output.
ResourcePlan DPM code reading on reflective metal parts by mark type, surface finish, lighting angle, reader distance, read-rate target and no-read handling.
ResourcePlan roll-to-roll film defect inspection by web width, line scan camera route, line light uniformity, encoder timing, smallest defect and false reject control.
ResourceDesign food and beverage inspection for cap presence, label position, date code readability, fill or package checks, line speed and reject reliability.
ResourceA beginner-friendly guide to choosing machine vision lighting by contrast, surface behavior and defect type.
Reference alternatives
Compare compact and embedded camera requirements by size envelope, interface, power budget and host platform.
CompareCompare combined optics, lighting and sensor routes when the inspection task is fixed and the geometry is tight.
CompareCompare an integrator-supplied build with a factory-direct component route when the integration work stays in house.
CompareA neutral selection guide for teams comparing Keyence-style integrated vision systems with component-level inspection routes.
CompareUse Basler camera reference demand to guide area scan, line scan, interface, resolution and lens decisions.
CompareSelect machine vision lighting by part surface, defect type, contrast method and mechanical installation constraints.
CompareMap fixed-mount barcode reader requirements to code type, speed, lighting and traceability constraints.
CompareReview Hikrobot-style camera, lens, lighting and barcode requirements against a factory-direct component route.
CompareMap SICK-style sensor and reader requirements to fixed barcode reading, smart camera and inspection cell needs.
ComparePlan fixed barcode reader selection for teams comparing Datalogic-style code reading with factory-direct options.
CompareUse Zebra scanner reference requirements to confirm code size, motion speed, lighting and mounting constraints.
CompareTranslate Teledyne DALSA-style area scan and line scan requirements into practical machine vision camera choices.
CompareCompare FLIR-style industrial camera needs with Deyi Vision camera, lens and lighting selection constraints.
CompareUse Allied Vision camera references to frame sensor size, interface, frame rate and machine vision application needs.
CompareMap IDS Imaging-style camera searches to inspection goals, optics, lighting and factory-direct RFQ inputs.
CompareReview Baumer-style vision camera requirements before selecting resolution, interface, lens and lighting route.
CompareTurn a distributor shortlist into camera, lens, lighting and interface requirements a factory can quote against directly.
CompareUse Stemmer-style component sourcing requirements to plan cameras, lenses, lights and integration-ready RFQ details.
CompareCompare Banner-style vision sensors with smart cameras, lighting and compact pass/fail inspection routes.
ComparePlan barcode reader selection for Omron Microscan-style DPM, label and traceability requirements.
CompareMap Balluff-style vision sensor needs to factory-direct smart camera, lighting and camera component choices.
Product RFQ
Send working distance, target size, speed, defect type, competitor model or sample images before locking a part number.
Request engineering RFQProduct FAQ
Start with the inspection goal, field of view, working distance, line speed and target tolerance. Then match machine vision lighting with lens, lighting, mounting and I/O requirements instead of choosing by part number alone.
Send good and bad sample images, target feature size, field of view, working distance, speed, trigger method, interface requirement and any current reference model. That lets engineering confirm whether machine vision lighting is the right route or whether another product family is safer.
Avoid catalog-only selection when the part is reflective, moving quickly, tolerance-sensitive, space-limited or already failing under manual inspection. In those cases, lighting, lens, fixture and software behavior often matter as much as the component specification.
Send part photos or drawings, target defect or measurement goal, field of view, working distance, line speed, accuracy target, lighting limits and any current camera, lens, light, barcode reader or competitor model.
Use 2D when contrast, edges, labels or position are enough to judge the part. Use 3D when height, profile, gap, volume, weld shape or surface geometry decides pass or fail.
Start from the defect and material surface instead of the camera model. Backlight helps edge measurement, coaxial and dome lighting help reflective surfaces, and bar or ring lighting often works for general presence and defect checks.