Product route

Machine Vision Systems

Camera, lens, lighting, barcode, 3D, controller and inspection software routes planned as one machine vision system for production RFQs.

Needs a complete inspection route, not one isolated camera, light or lens modelConfirm FOV, working distance, target defect, tolerance, line speed, trigger, interface and reject outputUse smart cameras for contained pass/fail logic
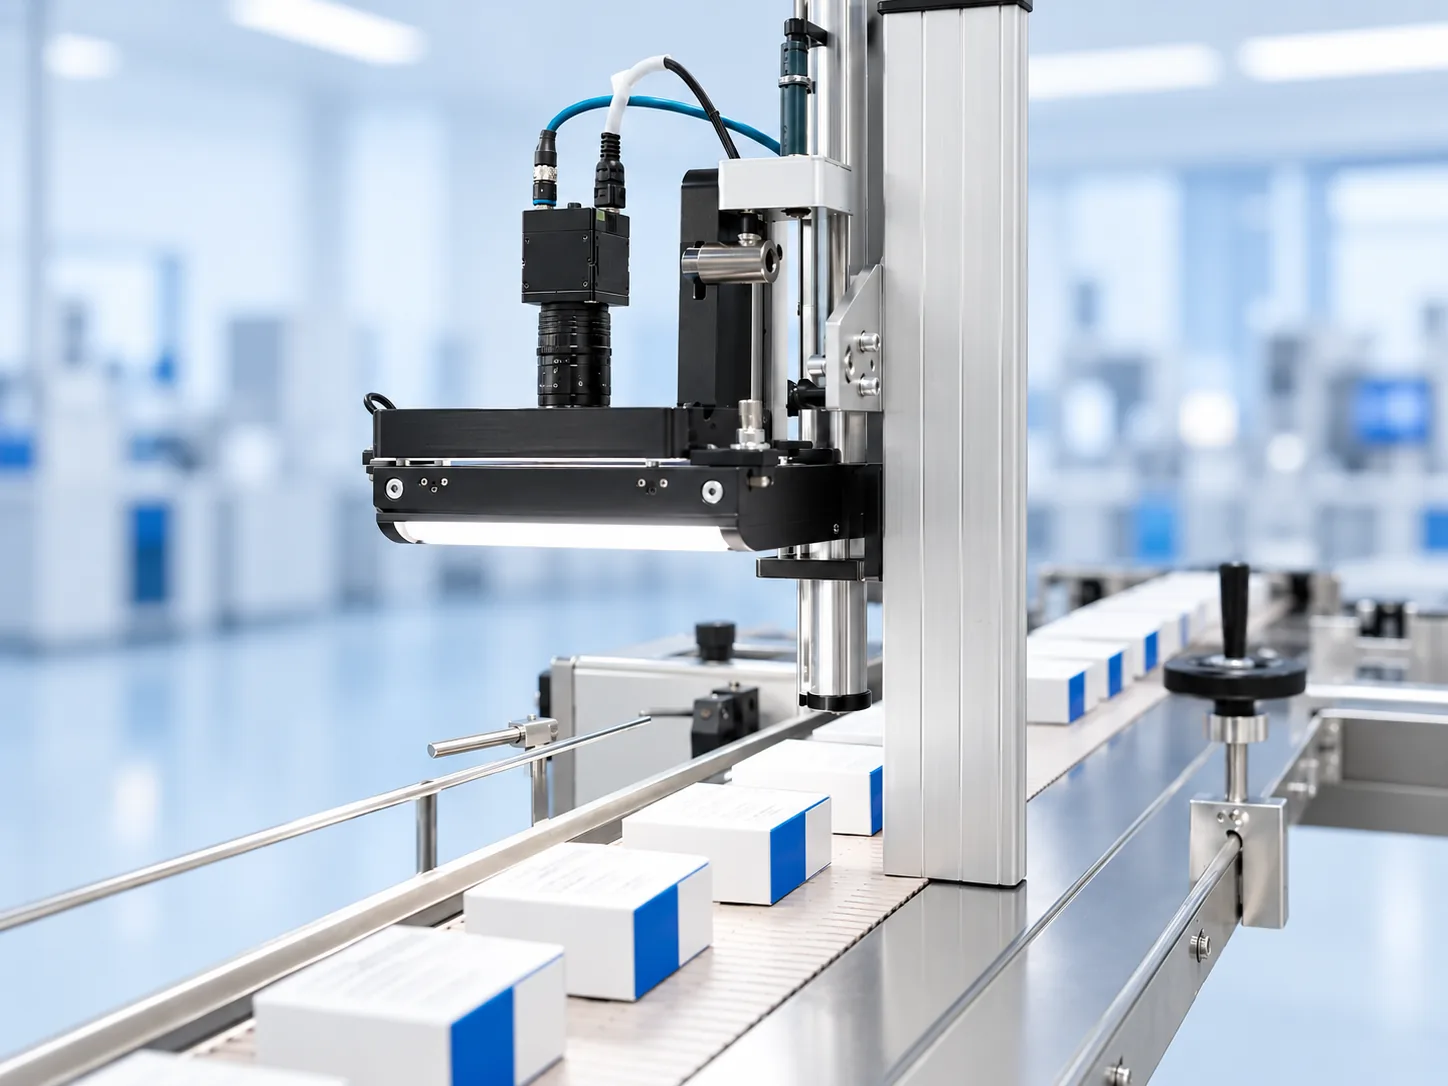
AI-enhanced product selection illustration: Machine Vision Systems
AI-generated or enhanced selection illustration. It does not show a customer installation, an exact supplied model or verified interchangeability.
Best-fit route

When to review machine vision systems.

The Machine Vision Systems route fits automated visual inspection, vision inspection system, barcode traceability, robot guidance, dimension measurement projects. Start from the production decision: pass, fail, measurement, code read, coordinate or height profile.

Key parameters

Confirm these before model selection.

Camera + lens + light, Inspection I/O, RFQ-ready route are only the starting point. Also confirm field of view, working distance, line speed, interface, trigger timing and mounting limits.

Evidence to prepare

Send evidence before asking for a part number.

Share sample images, good and bad parts, current reference model, target defect, tolerance, production speed and available fixture space.

When not to use this route

Where this route stops working.

  • Do not lock a model before sample images, line speed and target tolerance are available.
  • Do not treat the component as a standalone purchase when lighting, optics, fixture or trigger constraints are still unknown.
  • Do not assume a reference brand or catalog model proves production-line acceptance.
What engineering should confirm first

Send route evidence before asking for a final part number.

  • Part photos or short line video
  • Good and bad sample examples
  • Target feature size or tolerance
  • Field of view and working distance
  • Line speed, trigger and interface needs

When this route is a good fit

A machine vision system should be specified as camera, lens, lighting, trigger, controller, software and I/O together; Deyi maps the full route from sample evidence before quoting.

Use RFQ checklist
Best-fit signals

Use this route when the project matches these constraints.

Use when
The buyer needs a complete inspection route, not one isolated camera, light or lens model.
Core numbers
Confirm FOV, working distance, target defect, tolerance, line speed, trigger, interface and reject output.
Route split
Use smart cameras for contained pass/fail logic; use PC/controller routes for multi-camera or complex inspection.
Selection risks to check

Do not quote this route before these checks are clear.

  • Do not choose the camera before lighting and lens tests prove the image signal.
  • Do not request a final quote without sample images and acceptance criteria.
  • Do not compare brands only by model number when the inspection geometry is different.

Swipe horizontally to compare buyer situation, inspection constraint, recommended route and what to send.

Buyer situation Inspection constraint Recommended route What to send
System review for camera, lens, lighting, controller and pass/fail output Full inspection system RFQ System route for camera, lens, lighting, controller and pass/fail output. Send part photos, defect target, FOV, working distance, speed, tolerance and output requirement.
Inspection cell review for defect, presence, measurement, barcode and reject decisions Vision inspection station RFQ Inspection cell route for defect, presence, measurement, barcode and reject decisions. Confirm good/bad examples, acceptance criteria, reject method and integration protocol.
Camera review selected only after lens, lighting, trigger and interface are checked Automated quality-control project Camera route selected only after lens, lighting, trigger and interface are checked. Provide resolution target, smallest feature, interface preference and line speed.
RFQ review for buyers comparing component coverage, system review and export support Supplier selection review RFQ route for buyers comparing component coverage, system route and export support. List current model references, budget constraints, required documentation and test samples.

How buyers should compare this route

Build the product route around the inspection target, not the catalog model.

Open RFQ checklist
When this route is a good fit

Use machine vision systems when the inspection evidence matches the route.

Machine Vision Systems should be evaluated when the project is tied to automated visual inspection, vision inspection system, barcode traceability, robot guidance, dimension measurement. A useful review starts from the part behavior, target feature, motion condition and current failure mode, then maps those limits to the right component family instead of forcing one catalog model.

  • Automated visual inspection
  • Vision inspection system
  • Barcode traceability
  • Robot guidance
  • Dimension measurement
How buyers should compare this route

Compare constraints, not only specifications.

Use machine vision systems selection as a system decision: lens, lighting, fixture, trigger, interface and software all affect repeatability. The safest shortlist is created only after sample images, line speed and output constraints are reviewed together.

  • Start from the production decision: pass, fail, measurement, code read, coordinate or height profile.
  • Map camera, lens, lighting, trigger, controller and I/O together before locking model numbers.
  • Send sample images, line speed, tolerance, FOV, working distance and interface requirements for a usable RFQ.

What engineering should confirm first

Four checks before locking the machine vision systems route.

This workflow keeps the RFQ focused on the real inspection constraint and reduces the risk of buying a component that works on paper but fails under production lighting, motion or fixture variation.

  1. Define the inspection target State the defect, code, edge, height, presence check or measurement result that must be accepted or rejected.
  2. Lock optical and mechanical constraints Confirm field of view, working distance, mounting space, part motion, fixture stability and available light geometry.
  3. Match the component route Review machine vision systems with related lenses, lighting, controllers, I/O and software rather than selecting one part number in isolation.
  4. Validate with samples Use good parts, bad parts and edge-case samples to confirm contrast, repeatability, read rate or measurement stability before purchase.

Reviewed selection basis

Review model data, buyer constraints and acceptance risk before RFQ lock.

Manufacturer seriesMachine vision system route Selection basisDEYI camera, lens, lighting, reader, 3D and controller route Model routeDeyi-supported system route Buyer reference modelKeyence / Cognex / Basler / Omron
Quote variables

What changes the route, cost and delivery review.

Application route
Automated visual inspection, Vision inspection system, Barcode traceability, Robot guidance, Dimension measurement
Hardware scope
Camera + lens + light, Inspection I/O, RFQ-ready route
Buyer reference model
Keyence / Cognex / Basler / Omron
Risk checks

Common reasons product selection goes wrong.

  • Choosing by resolution, catalog size or brand reference before defining the inspection target.
  • Ignoring lighting, lens, fixture or trigger limits that decide whether the component can repeat on the production line.
  • Requesting a quote without good/bad sample images, line speed, target tolerance or the current failure mode.
Evidence to prepare

Evidence that helps engineering reply faster.

Part photos or short line videoGood and bad sample examplesTarget feature size or toleranceField of view and working distanceLine speed, trigger and interface needsCurrent model, competitor reference or failure mode

Related solution routes

Connect this product family to an inspection problem.

View all solutions

Application case briefs

Explore illustrative selection examples for this product family.

View all case briefs

Related buying guides

What to check before you quote this route.

View all resources
Resource

How to Choose Machine Vision Lighting

Choose machine vision lighting by surface finish, defect direction, camera angle, working distance and acceptance evidence instead of choosing by light shape alone.

Resource

Machine Vision System Components

Break down cameras, lenses, lighting, controllers, software, I/O and fixtures in an industrial vision system.

Resource

Industrial Barcode Reader Selection Guide

Select fixed industrial barcode readers by code type, module size, read distance, line speed, lighting route, trigger timing and no-read handling.

Resource

World Models for Industrial Metrology: What Is Ready Now?

An evidence-led guide to how metric 3D reconstruction, active view planning and uncertainty connect world models with traceable industrial vision metrology.

Resource

2D vs 3D Machine Vision

Compare 2D and 3D inspection methods for defects, dimension, height, volume and surface geometry tasks.

Resource

Industrial Camera Cross-Reference Selector

Translate a Basler, Allied Vision, Baumer, IDS or Teledyne datasheet into the four values that decide whether another camera fits: sensor format, pixel size, interface and shutter.

Resource

Machine Vision Camera Resolution Calculator

Estimate camera resolution from field of view, smallest feature size and measurement tolerance before selecting a sensor.

Resource

Machine Vision Camera Supplier Checklist

Evaluate a machine vision camera supplier by application review quality, sample evidence, optical route support and integration handoff.

Resource

Machine Vision Supplier Selection Guide

Choose a machine vision supplier by application engineering, sample testing, component route coverage, export support and integration documentation.

Resource

Industrial Camera Interface Guide

Compare GigE, USB3, line-scan and trigger I/O interface choices by cable length, bandwidth, frame rate, exposure timing and machine integration route.

Resource

Machine Vision Lighting Types

Compare ring, bar, dome, coaxial, backlight and line lighting types by surface behavior, defect contrast and installation constraints.

Resource

Fixed Barcode Reader vs Handheld Scanner

Compare fixed-mount barcode readers and handheld scanners for production lines, warehouses and traceability cells.

Resource

Barcode Reader for Manufacturing Lines

Select a barcode reader for manufacturing by code type, takt time, conveyor speed, read distance, trigger timing, PLC output and no-read handling.

Resource

DPM Barcode Reading Guide

Plan direct part mark code reading by material, mark type, contrast, lighting angle and reader mounting conditions.

Resource

Fixed Mount Barcode Reader Setup Guide

Plan fixed mount barcode reader setup by code size, conveyor speed, trigger method, mounting angle, lighting, DPM difficulty and read-rate target.

Resource

Vision Inspection RFQ Checklist

Collect the details engineering teams need before requesting cameras, lenses, lighting, readers or inspection systems.

Resource

Smart Camera vs PC-Based Vision System

Compare smart cameras and PC-based machine vision systems by inspection complexity, I/O, multi-camera logic, data handling, maintenance and expansion risk.

Resource

GigE vs USB3 Industrial Camera

Choose GigE when the camera is far from the host, the cell is distributed or industrial network routing matters. Choose USB3 when the camera is close to the host and the application needs short-cable high-bandwidth acquisition with controlled cable routing.

Resource

Laser Profiler Selection Guide

Select laser profilers and 3D profile sensors by profile width, height range, Z resolution, speed, surface reflectivity, mounting angle and repeatability target.

Resource

Line Scan Camera with Encoder Setup

Plan a line scan camera with encoder synchronization by web speed, pulse rate, roller diameter, line rate, exposure and image scale stability.

Resource

Visual Inspection System Design Checklist

Design a visual inspection system by defining defect criteria, sample set, optics, lighting, fixture, trigger, I/O and acceptance tests.

Resource

Machine Vision Acceptance Test Checklist

Define machine vision acceptance tests with good/bad samples, repeatability checks, false-pass risk, read-rate targets, station timing and integration handoff notes.

Resource

Flexible Feeder Robot Loading for Small Parts

Plan flexible feeder robot loading for screws, terminals, contacts and small molded parts by part behavior, tray route, vision positioning and pickup repeatability.

Resource

EV Battery Weld Height Inspection with 3D Vision

Plan EV battery weld-height inspection by profile width, Z tolerance, reflective surface behavior, trigger timing and reject output.

Resource

DPM Code Reading on Reflective Metal Parts

Plan DPM code reading on reflective metal parts by mark type, surface finish, lighting angle, reader distance, read-rate target and no-read handling.

Resource

Pharmaceutical Packaging Code Label Seal Inspection

Plan pharmaceutical packaging inspection for code verification, label position, seal presence, carton checks, rejection behavior and documented acceptance.

Resource

What Is Machine Vision?

Machine vision is an automated way to inspect products with cameras, lenses, lighting and software so a production line can measure, locate, accept, reject or trace parts.

Resource

How Does a Machine Vision System Work?

Follow the machine vision workflow from trigger and image capture to lighting, processing, decision output and RFQ evidence.

Reference alternatives

Compare this product family against reference-model requirements.

View all comparisons

Product RFQ

Need help selecting machine vision systems?

Send working distance, target size, speed, defect type, competitor model or sample images before locking a part number.

Request engineering RFQ

Product FAQ

Common questions before selecting machine vision systems.

Ask engineering
How do I confirm whether machine vision systems fit my project?

Start with the inspection goal, field of view, working distance, line speed and target tolerance. Then match machine vision systems with lens, lighting, mounting and I/O requirements instead of choosing by part number alone.

What information improves machine vision systems selection accuracy?

Send good and bad sample images, target feature size, field of view, working distance, speed, trigger method, interface requirement and any current reference model. That lets engineering confirm whether machine vision system is the right route or whether another product family is safer.

When should I avoid selecting machine vision systems by catalog specs only?

Avoid catalog-only selection when the part is reflective, moving quickly, tolerance-sensitive, space-limited or already failing under manual inspection. In those cases, lighting, lens, fixture and software behavior often matter as much as the component specification.

What information should I send before requesting a machine vision quote?

Send part photos or drawings, target defect or measurement goal, field of view, working distance, line speed, accuracy target, lighting limits and any current camera, lens, light, barcode reader or competitor model.

Do I need a 2D or 3D machine vision system?

Use 2D when contrast, edges, labels or position are enough to judge the part. Use 3D when height, profile, gap, volume, weld shape or surface geometry decides pass or fail.

How should I choose machine vision lighting?

Start from the defect and material surface instead of the camera model. Backlight helps edge measurement, coaxial and dome lighting help reflective surfaces, and bar or ring lighting often works for general presence and defect checks.

Review the workflow behind the image.

For supported PC barcode tasks, compare confirmed samples and parameter trials in the DeYiVision visual workflow workbench. Camera compatibility and production acceptance require a separate project review.

Continue troubleshooting

Contact

Direct RFQ contact

Talk to engineering about the inspection problem.

Send sample images, competitor model, FOV, working distance and line speed before model selection.

Target: selection brief within 24h
Send sample images