Freeze the visible assembly acceptance claim
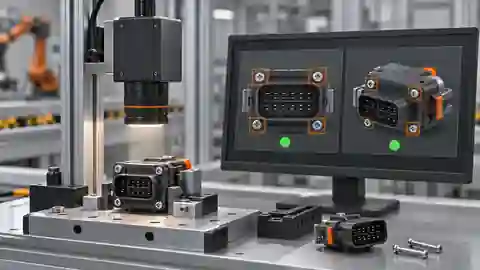
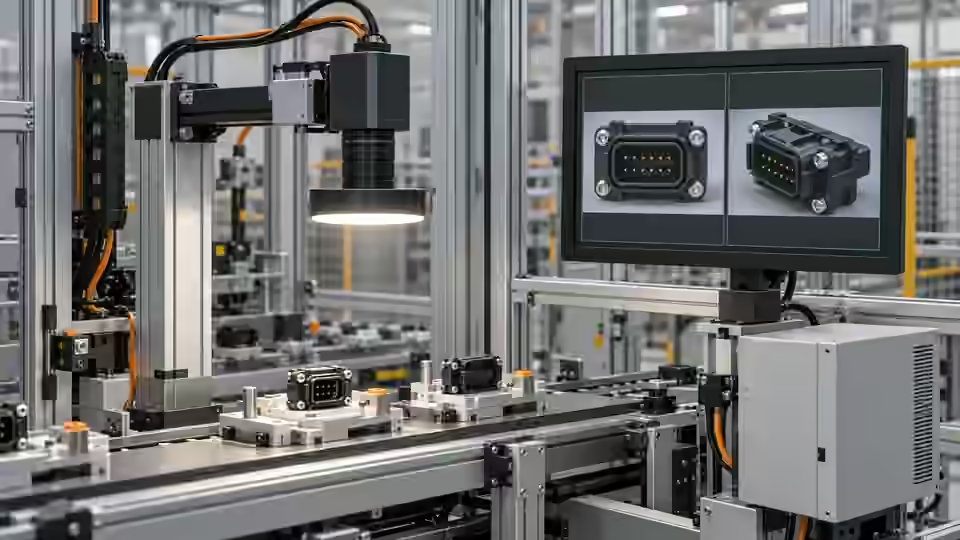
Freeze the acceptance claim around required visible parts and the declared image-space relationship in an identified fixture and assembly family. List hidden properties separately: apparent presence does not establish fastening torque, internal engagement, electrical contact or bond strength. If a physical spatial tolerance is claimed, its calibrated coordinate basis and applicable plane need their own evidence rather than an assumed conversion from an image interval. Agree allowed pose, surface appearance and visibility before the run. A receiving engineer must know precisely which assembly defects this inspection is intended to distinguish and which mechanical tests remain necessary outside the camera workflow.
Reserve independent case groups
Reserve independently identified assemblies and material or fixture groups that were not used to choose camera, light, zones or rules. Include correct visible assembly, required-part absence, misplaced relation, allowed variation and intentionally unobservable cases. Keep reference assessment independent of the selected workflow and declare how uncertain references will be handled. Repeated views of the same specimen must not be reported as independent assemblies. Do not exchange a difficult acceptance specimen for a cleaner development example. Freeze the planned case groups and operating conditions before selecting the final graph, and document unavailable or unresolved groups alongside the reported scope.
Cover the complete rule decision branches
Cover Pass, Fail and Review with explicit reference expectations and preserve execution errors or unavailable outputs separately. The reviewed bounded relationship route first requires valid visibility, then unique candidates for its declared labels. Multiple candidates lead to review rather than choosing the most convenient pair; an absent required label under valid observable evidence leads to failure. Test the intended branch, not just whether the display turned green. Malformed inputs must not quietly become an empty valid detection set. Confirm native output contracts against the installed versions and keep rule reasons available so a downstream integration cannot reinterpret ambiguity as a trustworthy passing result.
Acceptance stops at the visible assembly boundary
Required visible parts and their declared relationship must remain observable; hidden mechanical properties need other evidence.
- Declared fixture and assembly family
- Visible required component evidence
- Accepted image-space relationship
- Hidden torque or engagement outside scope
Test inclusive relationship boundaries
Check relationships at the declared inclusive limits and on the relevant outside cases using controlled image evidence. Retain label order, center definition, signed or unsigned relation and original-coordinate transform. A test exactly at a configured endpoint establishes the rule's comparison behavior; it does not establish the accuracy of a physical measurement or the suitability of that endpoint for the process. Separate synthetic rule checks from independently assessed assembly images in the report. If the chosen relation reverses with label order or changes under a crop revision, preserve that condition and validate the corrected configuration before treating later outputs as equivalent to the accepted chain.
acceptance_row = {
    'specimen_id': specimen_id,
    'reference_class': reference_class,
    'event_id': event_id,
    'image_id': image_id,
    'graph_revision': graph_revision,
    'raw_rule': raw_rule,
    'execution_status': execution_status,
    'receiving_action_status': receiving_action_status,
}
# Evidence schema only. Review, missing and malformed results remain distinct and nonpassing.
Preserve references and the planned denominator
Keep the complete planned denominator for valid decisions, review, execution failures and missing results. Count specimen outcomes separately from repeated image observations and retain the trace from every result to its reference and original source frame. A summary that excludes ambiguous fixtures can conceal the very condition the station must handle. Do not publish an assembly accuracy percentage from convenient valid outputs alone. The record below is a proposed evidence schema, not measured performance. Acceptance limits and the handling of unresolved cases must come from the agreed application risk and test plan, with explicit owners for gaps that remain outside the demonstrated inspection.
Verify station-specific handoff
Trace assembly identity through capture event, image, graph revision, raw rule and acknowledged receiving action. Check startup, stop, restart, missing frames, late results and cancellation in an isolated test environment before enabling equipment outputs. A correct visible decision delivered for another assembly has not passed integration. Preserve late and unavailable results as declared nonpassing conditions, without reusing a previous passing frame or suppressing the raw review reason. The controller's action, acknowledgement and timeout policies require a station-specific validated interface; this tutorial does not supply a universal actuator command or claim that saved-image tests have exercised the physical station.
Package reproducible acceptance evidence
Package independent specimen groups, reference rationale, original images, fixture and crop definitions, actual camera and light settings, graph and runtime identities, model assets where used, raw typed evidence, rule configuration and event logs. Include failures and unresolved ambiguity, not only preferred annotated screenshots. Keep the accepted baseline and candidate comparison reproducible by another engineer. The table identifies what travels with each evidence layer and where the claim stops. Any subsequent change to fixture, optics, class mapping, model, zone or output handoff needs a recorded impact assessment and appropriate revalidation; retaining the same workflow name is not enough to preserve the accepted behavior.
| Evidence layer | Association required | Limit retained |
|---|---|---|
| Independent assembly references | Specimen, fixture and defect class | Only observable declared properties |
| Raw part and relation evidence | Original image, transform and rule revision | Review remains ambiguity, not acceptance |
| Synthetic interval checks | Exact configuration and expected branch | Comparison behavior is not physical accuracy |
| Station action record | Assembly event and acknowledgement | Offline replay is not physical handoff proof |
Release only the demonstrated assembly scope
Release only the visible defects, assembly family, allowed operating conditions and interface behavior actually demonstrated by the agreed evidence. Historical bounded fixed-station source tests do not certify the current Windows candidate, real camera or installed production package. Browser-local OpenCV.js is not implemented in the reviewed scope, and model or cloud proposals need separately supported execution and acceptance. If hidden quality remains essential, keep its independent mechanical test rather than widening the visual claim. Deyi Vision can assist supported workflow investigation and evidence comparison, but an accepted visible relation is a specific result with limits, not a general guarantee of complete assembly quality.
From independent specimen to bounded release
Keep decision branches and event handoff separate before accepting the demonstrated station scope.
- Freeze independent references and limits
- Verify valid and ambiguous decision branches
- Confirm assembly-specific receiving action
- Accept demonstrated scope and retain gaps
Sources and technical references
These references explain the methods and limits used in this tutorial. Example checks are guidance; production acceptance requires evidence from your own samples.
- Camera CalibrationOpenCV
Physical interpretation of image geometry requires an explicitly validated calibration scope.
Checked - Triggered Image AcquisitionBasler
Physical acquisition and frame readiness must be verified separately from saved-image replay.
Checked - Deyi Vision Vision WorkbenchDeyi Vision
Supported offline workflow evaluation is not proof of released station or model readiness.
Checked
Component and selection references
- machine vision software
- Machine Vision Acceptance Test Checklist
- Automated Visual Inspection
- EAN-13 traceability: decode and data rules
- Stable camera acquisition: buffers, timeouts and reconnection
- Accept and integrate a visible fill-level workflow
- AI-assisted workflow for a visible level proxy
- Link inspection records, images and part identifiers
- OCR labels: acceptance and PLC contract
- OCR labels: native workflow and exact match
- Accept and integrate open-package completeness checks
- Build an AI-assisted open-package completeness workflow
- Build a PLC–vision handshake with explicit states
- Seal and bead appearance: line acceptance
- Seal and bead appearance: workflow rules
- SKU color sorting: acceptance and unknown route
- SKU color sorting: typed color and SKU rules
- Surface defects: acceptance and line output
- Surface defects: bounded AI evaluation
- Load-test latency from trigger to PLC decision
- Version and roll back the complete vision recipe